 01
Flagship / Robotics & Control
Two-DOF SCARA Robot
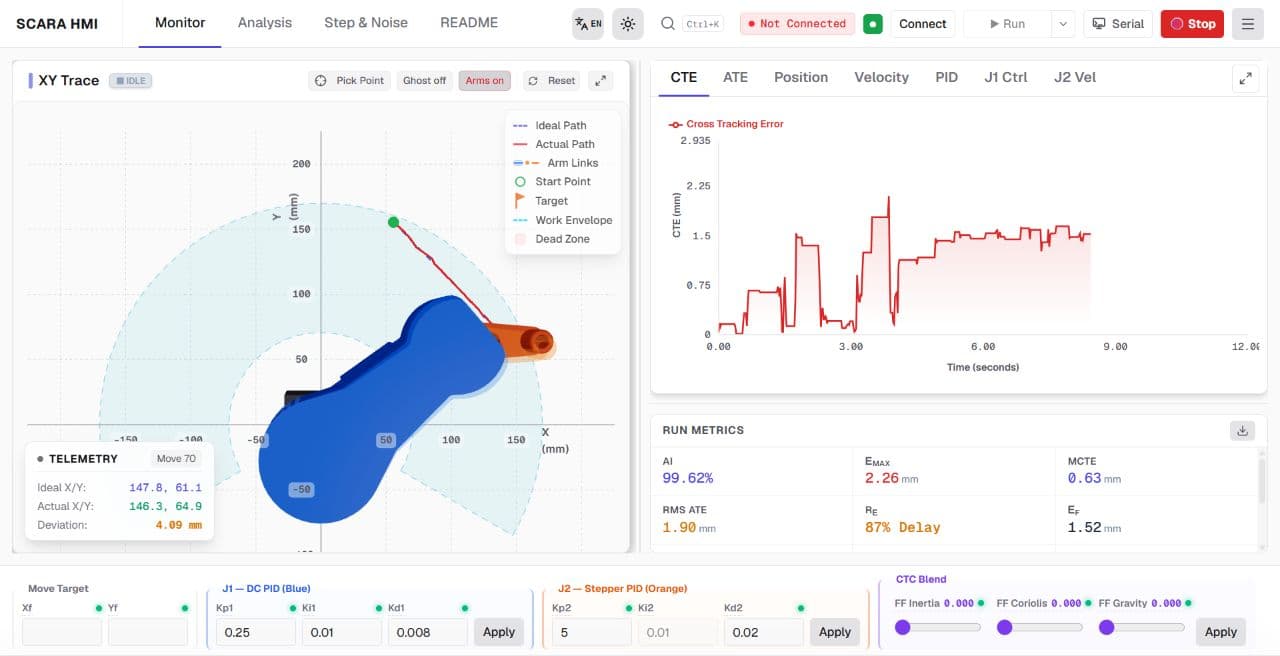
A planar teaching robot developed as one connected system: mechanical hardware, embedded control, telemetry, experiments, and a browser-based operator interface.
Field noteRobotics
My robotics work begins with the mechanism and continues through actuation, firmware, control logic, telemetry, and experimental validation.
The interface is not an afterthought. A well-designed HMI makes machine behavior inspectable, while disciplined data capture turns operation into evidence.
01Relevant work
01Flagship / Robotics & Control
A planar teaching robot developed as one connected system: mechanical hardware, embedded control, telemetry, experiments, and a browser-based operator interface.
 02
Supporting / Mechatronics HMI
A monitoring interface for a flywheel energy-storage concept, combining MQTT telemetry, time-series views, and a Three.js digital twin.
 03
Supporting / Industrial Automation
A browser-based conveyor HMI connecting MQTT machine data, operator controls, diagnostics, and persisted application state.
02Working range
Capabilities are paired with the decisions they support, not presented as an ungrounded technology inventory.
Reason from geometry, loads, assembly constraints, and actuation before choosing software abstractions.
Develop firmware and telemetry around the timing and sensing constraints of the physical system.
Structure controllers and test conditions so changes can be compared and explained.
Build HMIs that help operators understand state, commands, and system limits.